Sensors for Robots and AGVs
Service robots, cleaning robots, lawn mowers and AGVs use ultrasonic and laser distance sensors to avoid obstacles, and inertial sensors to hold their heading.
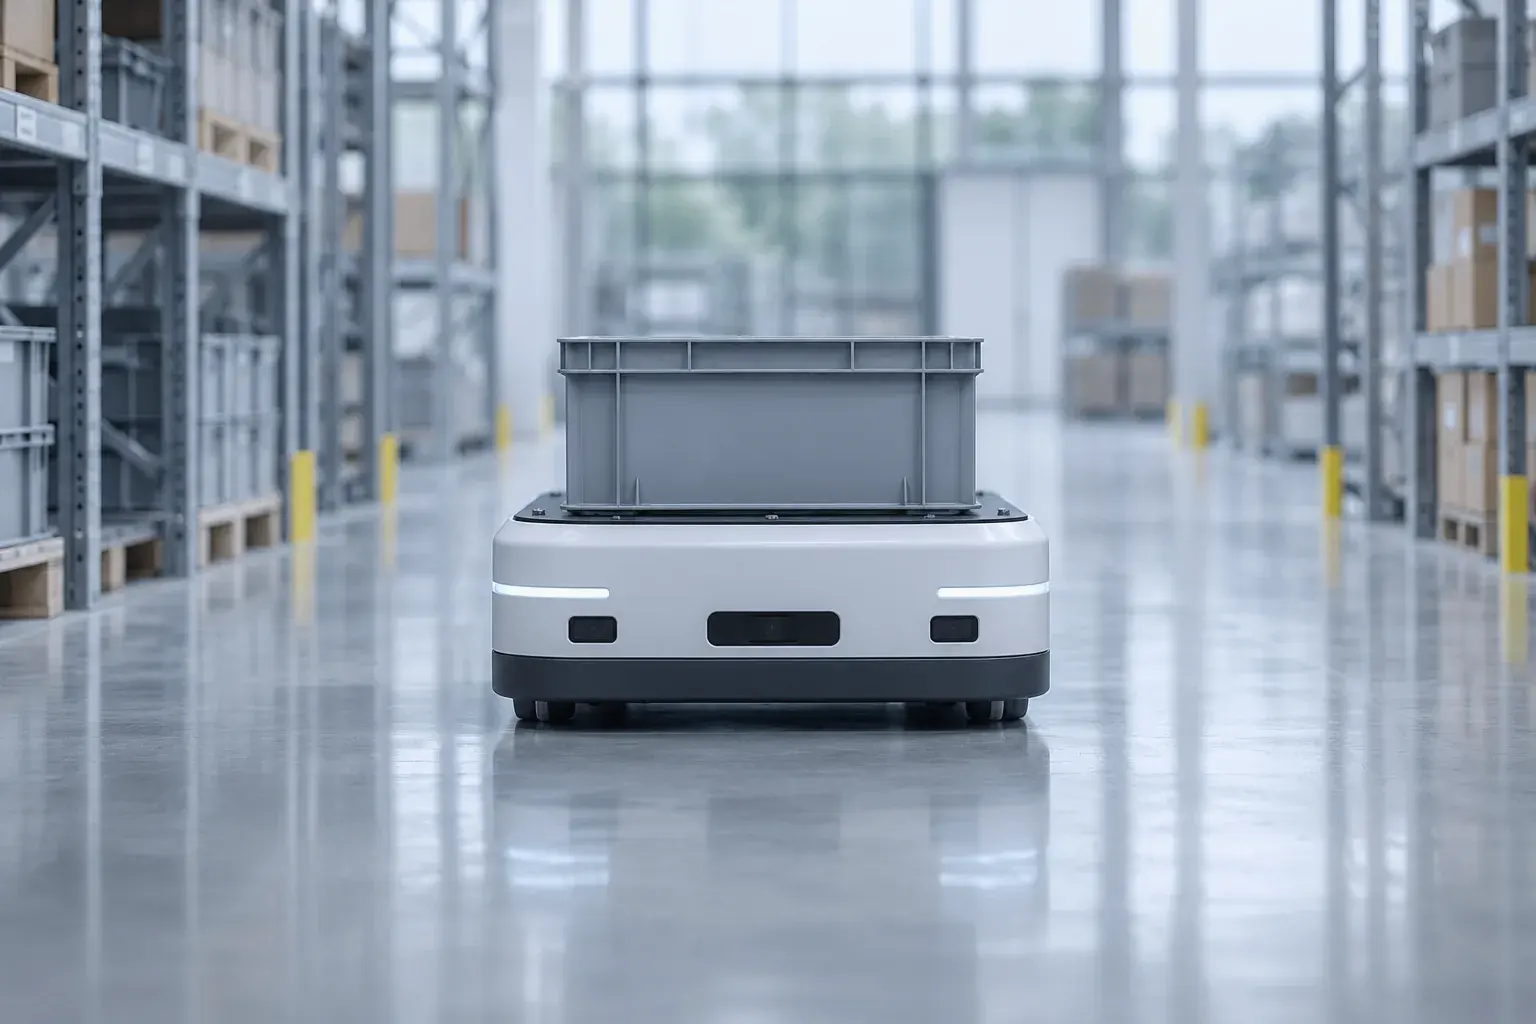
Sensor families for this application
- Ultrasonic distance sensors
- Non-contact ranging modules from a few centimetres to several metres, waterproof options.
- Laser distance sensors
- Optical time-of-flight sensors for small targets and narrow beams.
- Inertial sensors
- Accelerometers, angular rate sensors, inclinometers, vertical gyros and IMUs.
Models used here
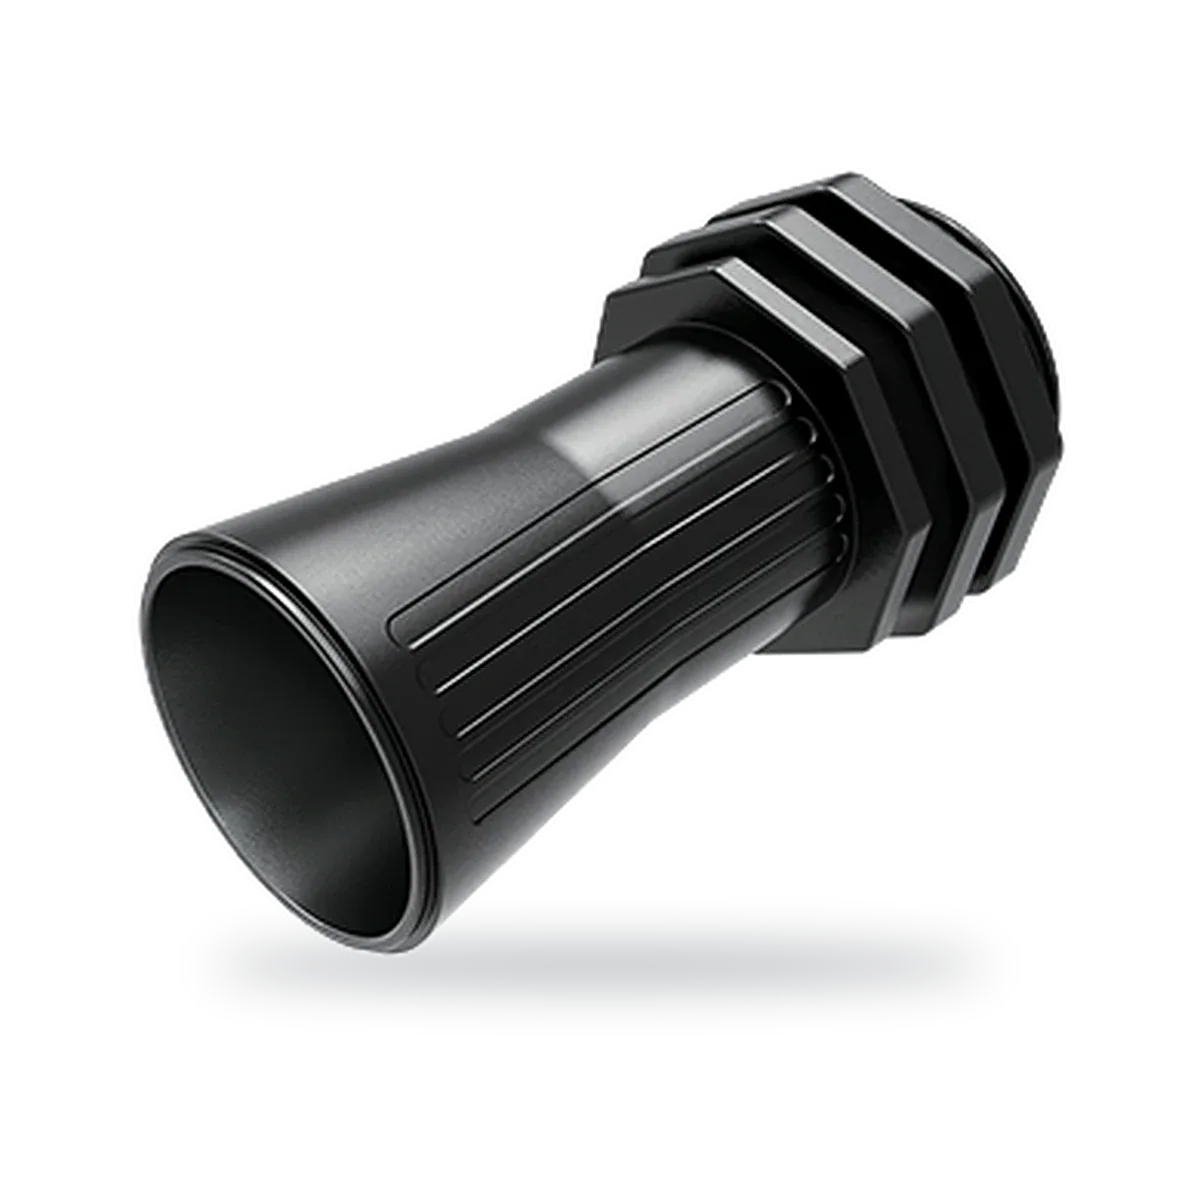
A01-V2.0
Waterproof Ultrasonic Distance Sensor, Optional Horn, IP67
- Range
- 28-450 cm
- Accuracy
- ±(1+S* 0.3%)
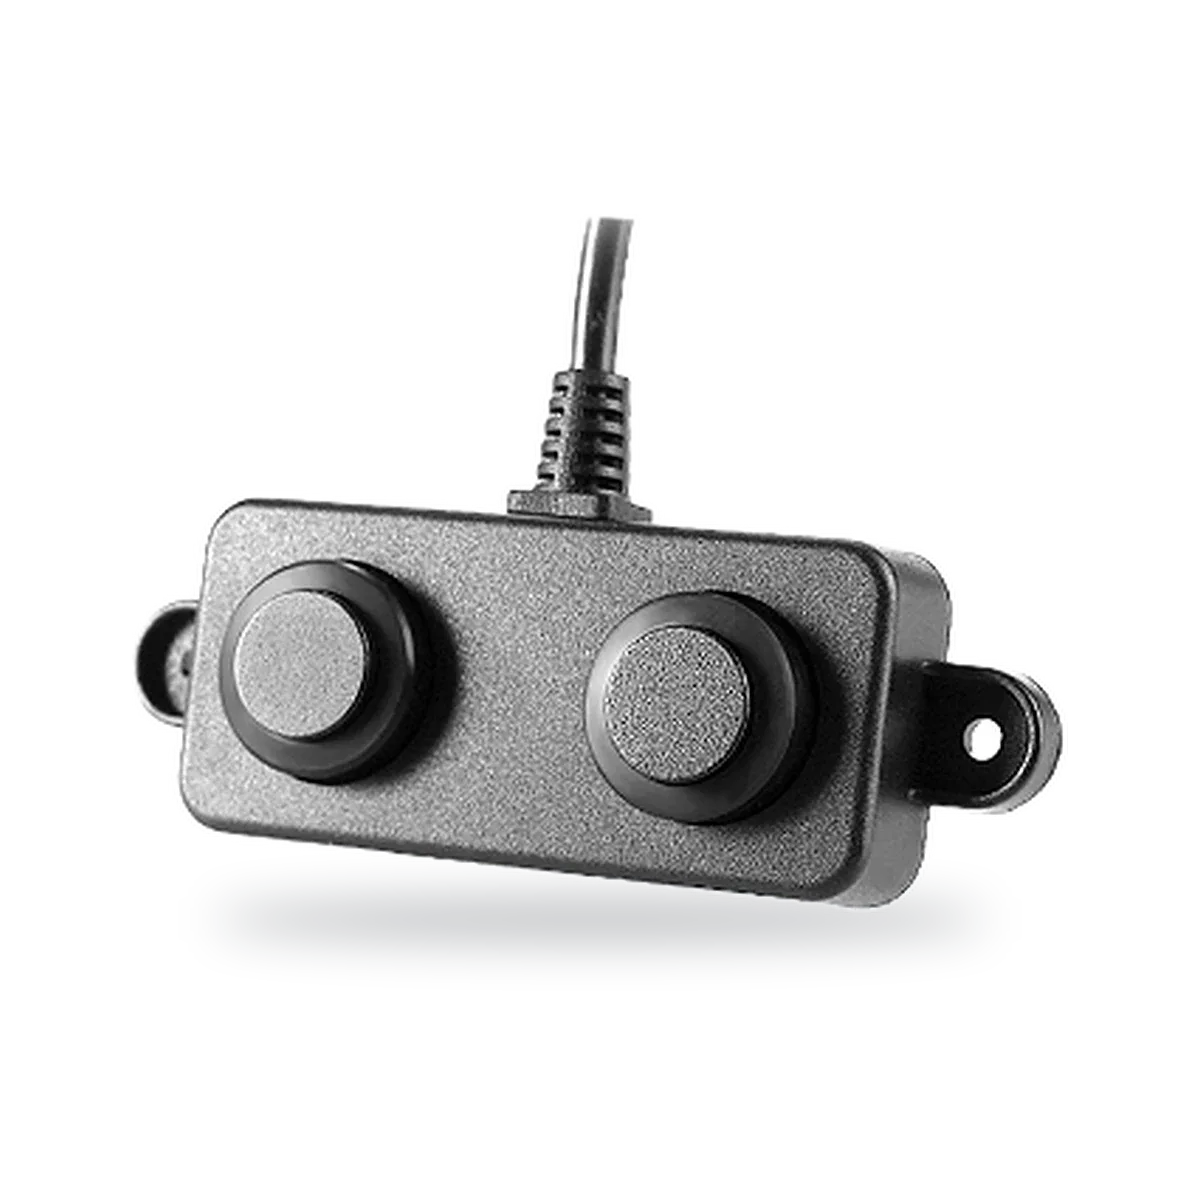
A02-V2.0
Split Waterproof Ultrasonic Distance Sensor, Housed
- Range
- 3cm-450cm
- Accuracy
- ±(1+S* 0.3%)
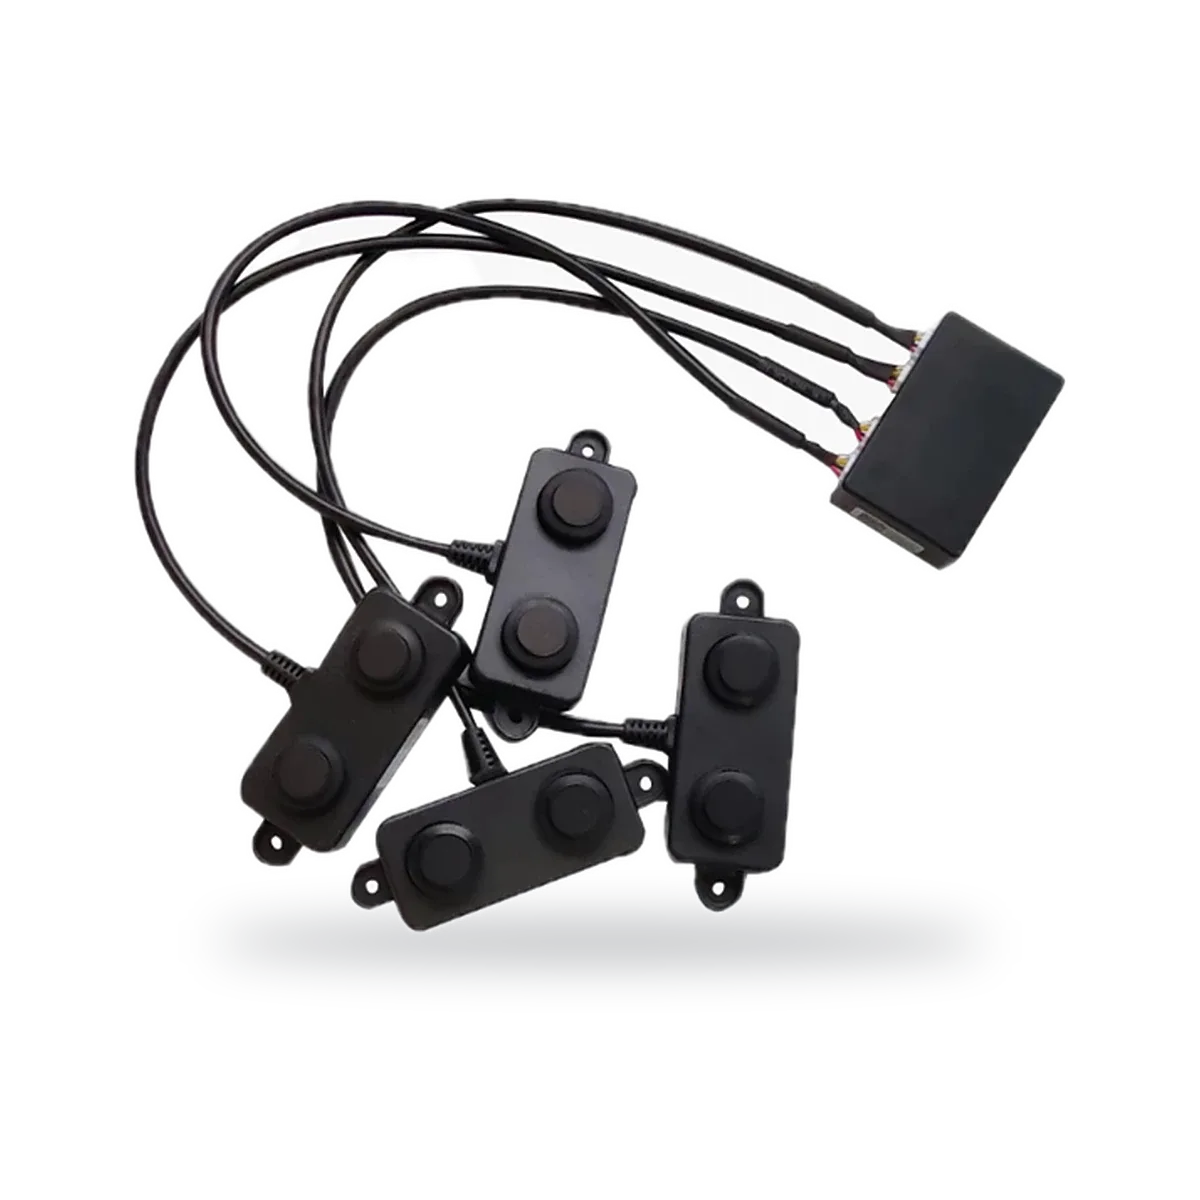
A02-V2.0
Small Blind-Zone Ultrasonic Obstacle-Avoidance Sensor
- Range
- 3–450 cm
- Accuracy
- ±(1+S*0.5%) cm
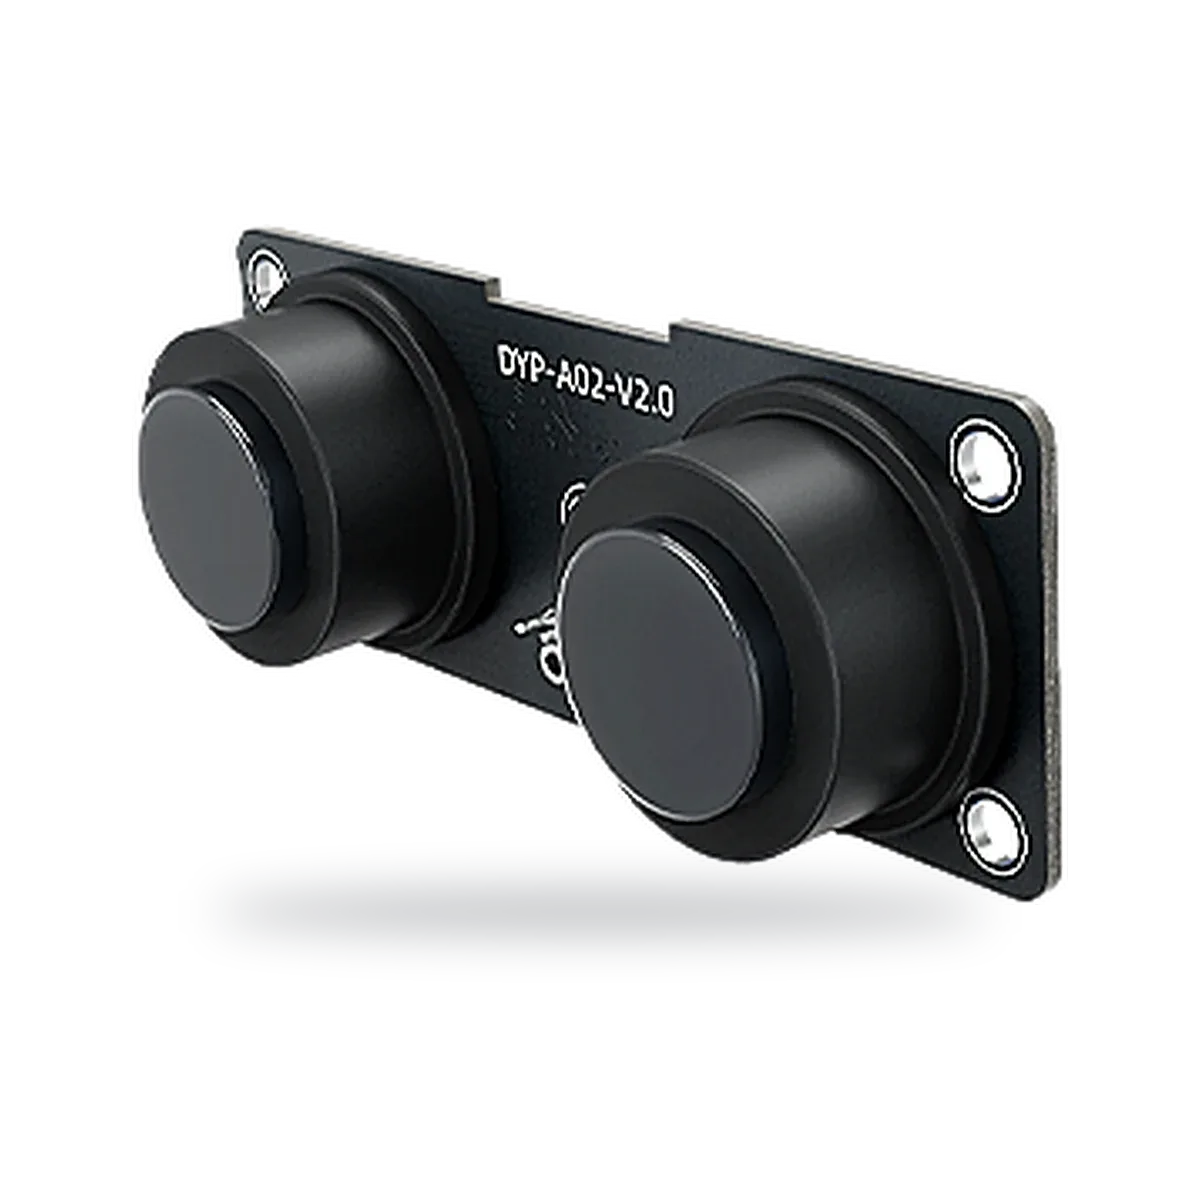
A02YY-V2.0
Split Waterproof Ultrasonic Module, No Housing
- Range
- 3cm-450cm
- Accuracy
- ±(1+S* 0.3%)
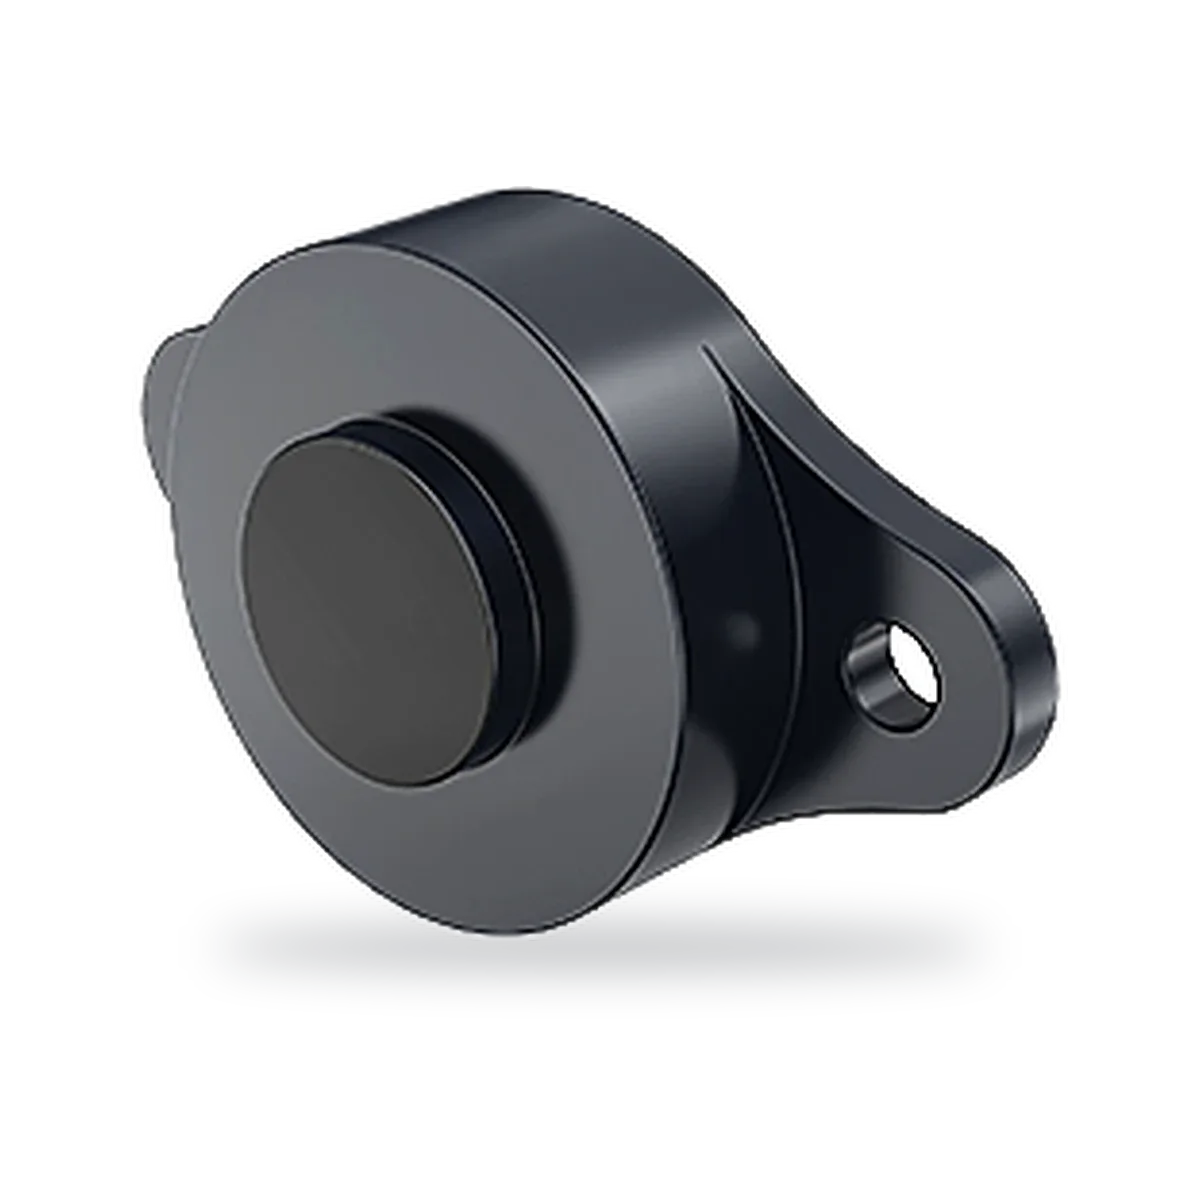
R01-V1.0
Waterproof Laser Distance Sensor, 2 to 400 cm, IP67
- Range
- 2–400 cm
- Blind zone
- 2 cm
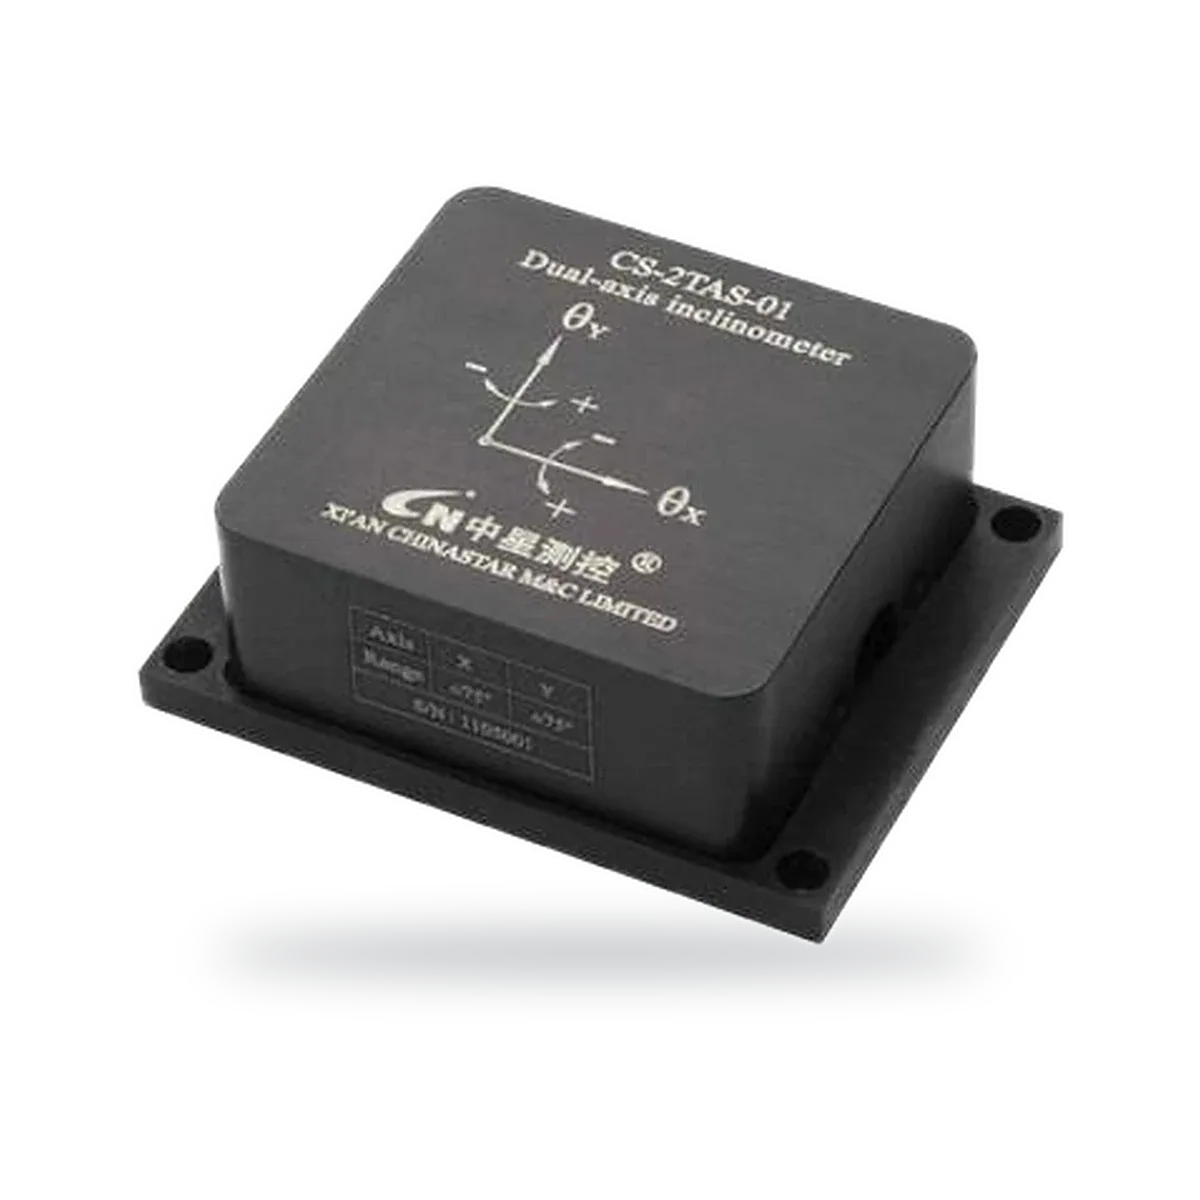
CS-2TAS-01A/B/D/F/G
Dual-Axis Inclinometer, Voltage, Current or Digital Output
- Output
- 0.5–4.5V, Voltage output
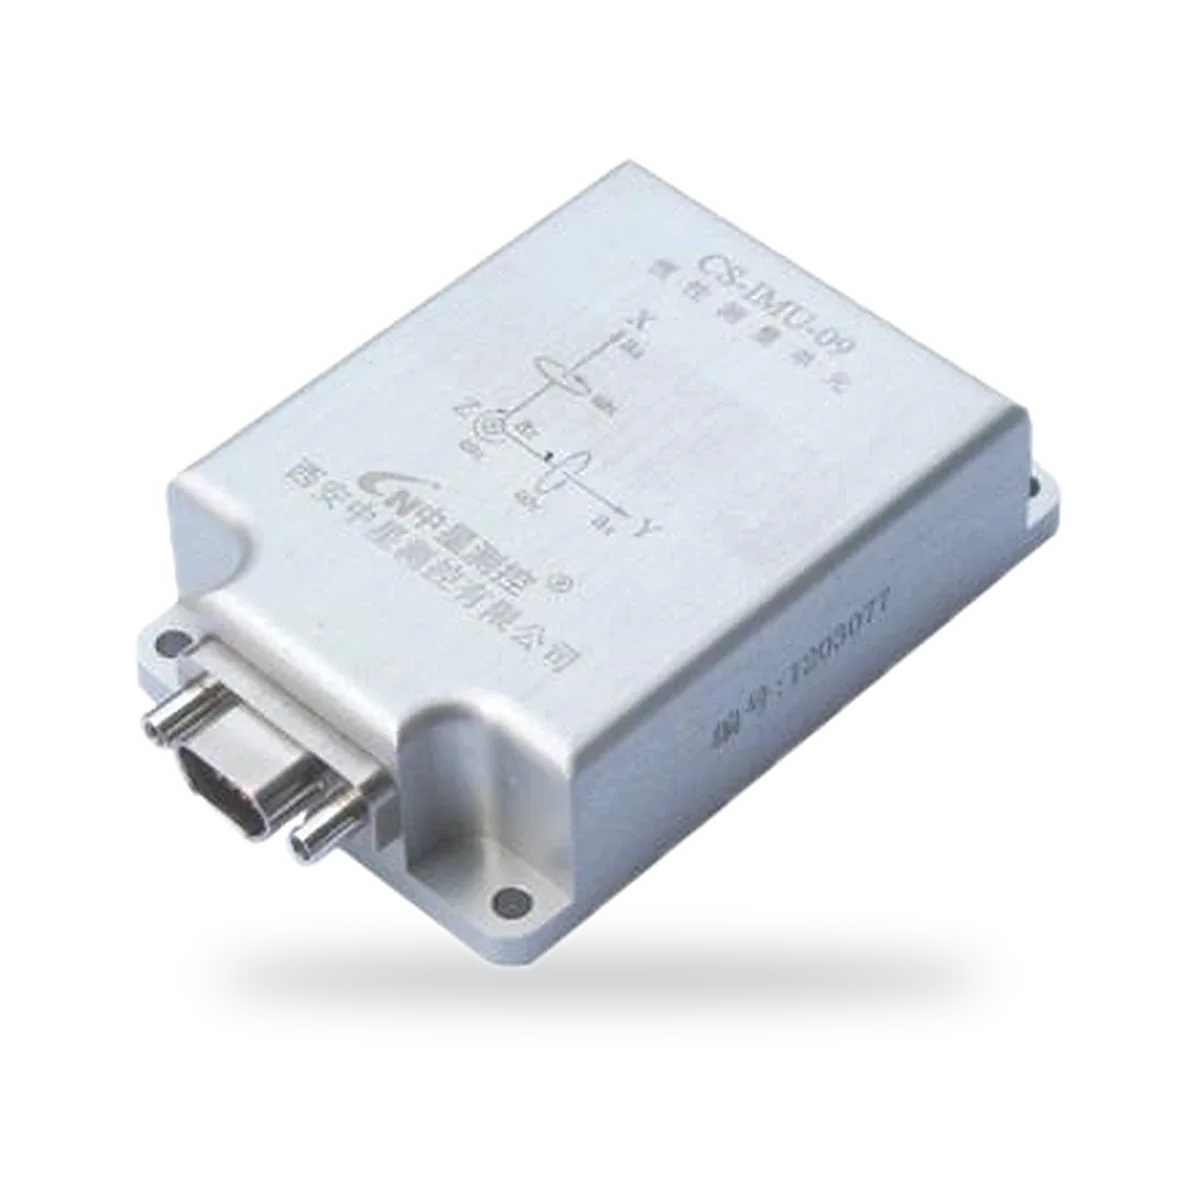
CS-IMU-09
Inertial Measurement Unit for Overhead Line Galloping
- Range
- ± 250 ° / s
- Output
- UART (TTL level)
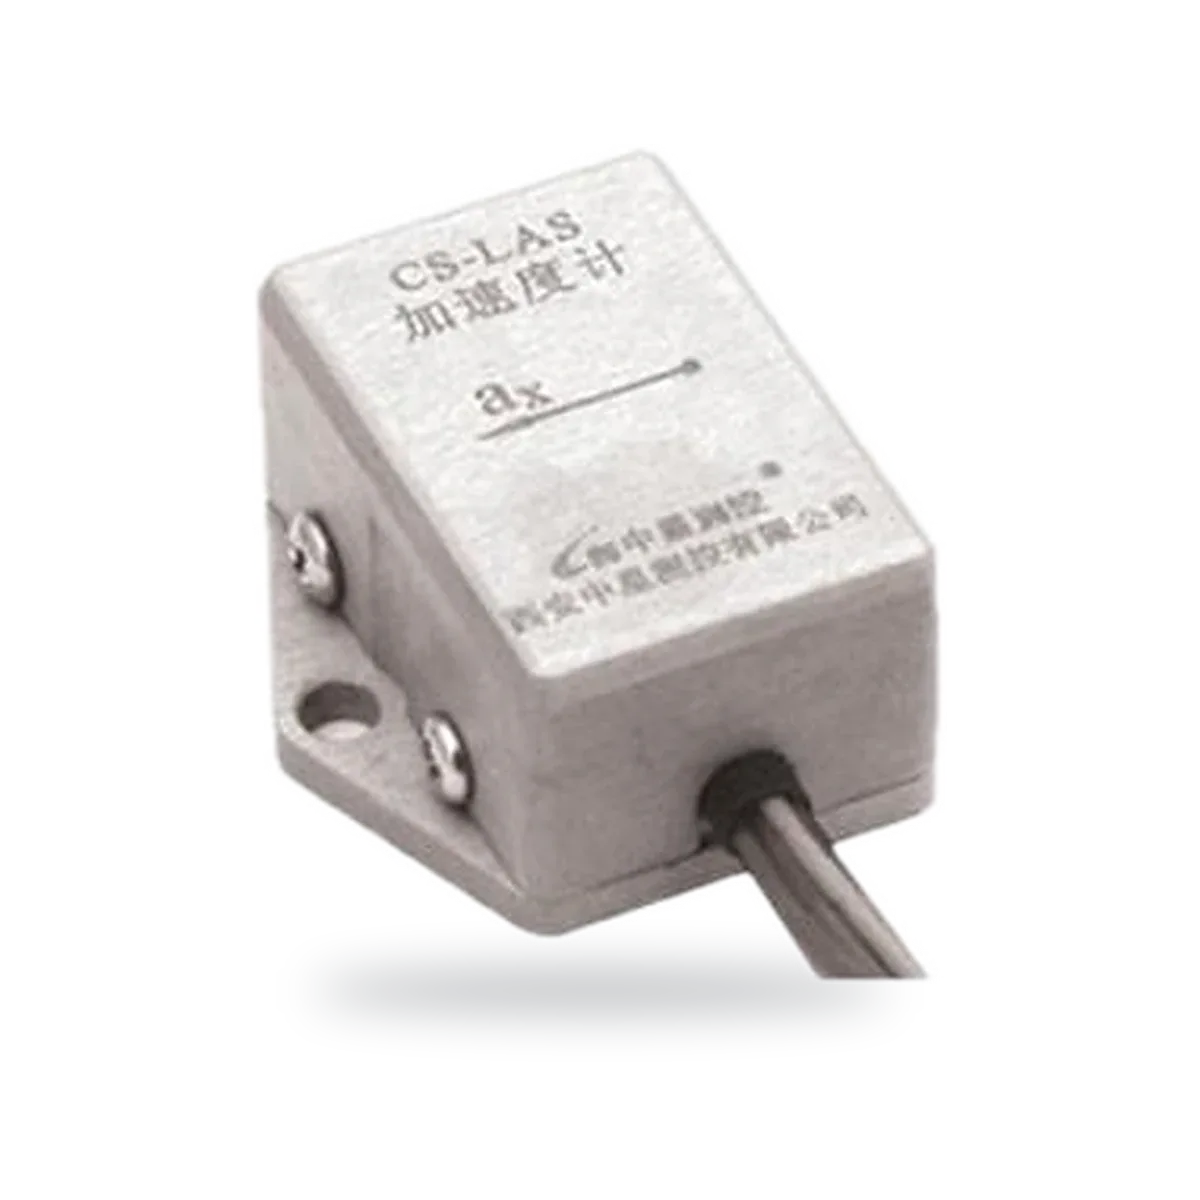
CS-LAS
Single-Axis Accelerometer, 0.5–4.5V Analog Output
- Output
- 0.5–4.5 V
- Supply voltage
- 5 ± 0.25 VDC
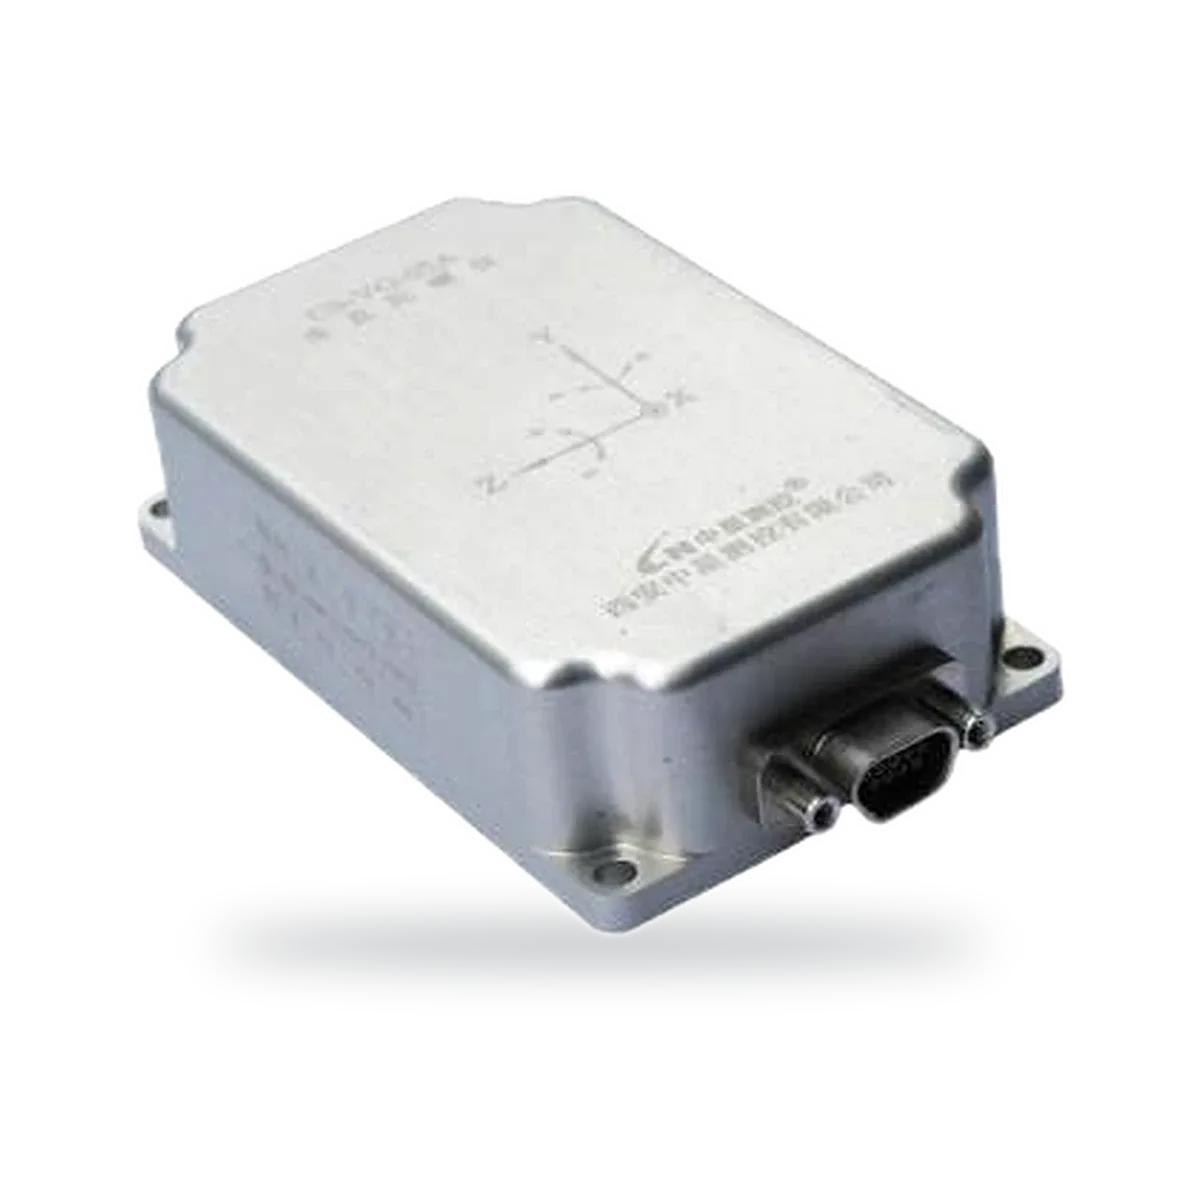
CS-VG-05
Vertical Gyroscope, RS422, Roll ± 180°, Pitch ± 90°
- Range
- ± 180 °
- Accuracy
- <0.8 °